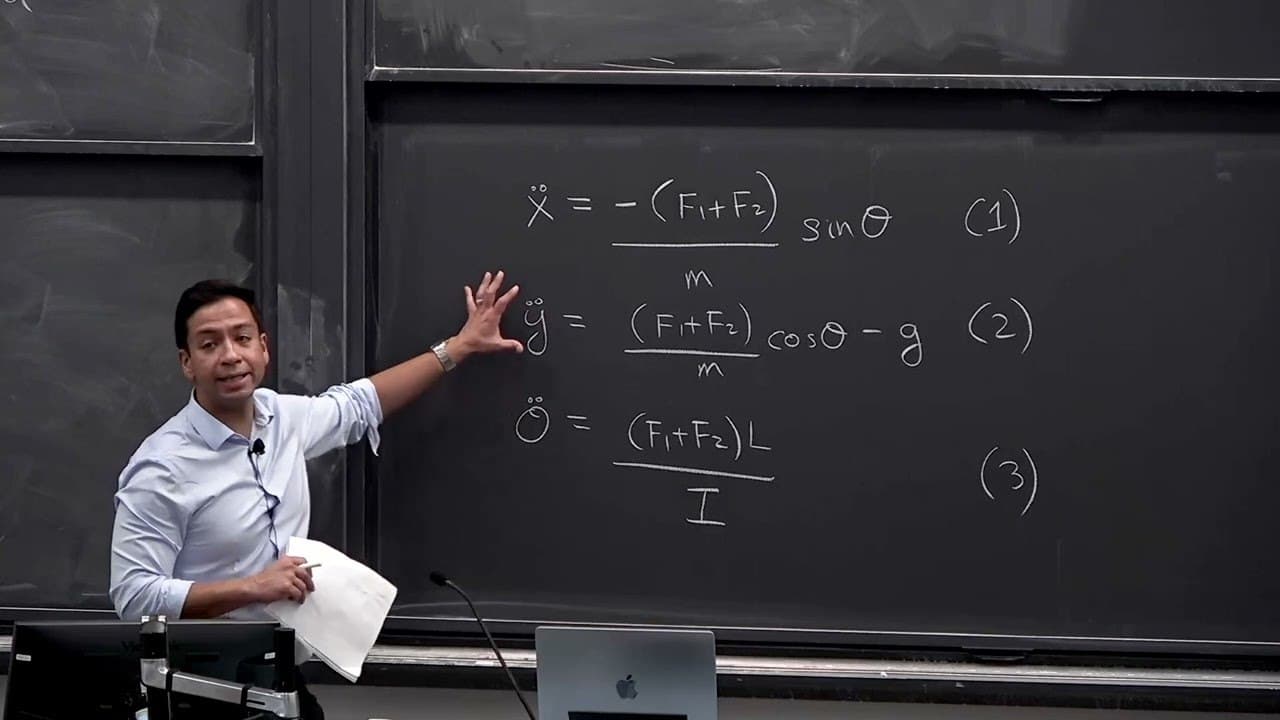Continuing the Princeton course Introduction to Robotics. This time, one lecture - about differential flatness. The idea is beautiful: for a quadcopter, it's enough to set a smooth trajectory of just four quantities (x, y, z, and yaw rotation), and everything else - inclinations, speeds, motor thrust - can be simply calculated from it. Thus, planning a complex flight reduces to drawing a smooth curve.
🎥 To watch:
Lecture 5 - Differential flatness, 67 min: https://youtu.be/64Rfzm359Xg
📆 Monday, November 2, 10:30am ET / 6:30pm MSK
⚠️ The US switches to winter time, so it's an hour later in Moscow than last time
📍 Registration (Luma): https://luma.com/g9cn4p7h
📺 Missed the last meeting? Recording of the discussion of lectures 3–4: https://youtu.be/yN0dO-vJ1dw
Questions during the viewing - in the chat @rvnikita_blog_chat
#robotics@rvnikita_blog #education@rvnikita_blog #ai@rvnikita_blog #princeton@rvnikita_blog